Understanding Microchip 8-bit PIC Configuration
The second post of a five part series picks up getting started developing with Microchip 8-bit PIC Microcontroller by examining the how and why of processor configuration. Topics discussed include selecting the oscillator to use during processor startup and refining the configuration once the application starts. A walk through of the code generated by the Microchip IDE provides a concrete example of the specific Configuration Word and SFR values needed to configure the project specific clock configuration.
Getting Started With Zephyr: Devicetree Overlays
In this blog post, I show how the Devicetree overlay is a valuable construct in The Zephyr Project RTOS. Overlays allow embedded software engineers to override the default pin configuration specified in Zephyr for a particular board. In this blog post, I use I2C as an example. Specifically, I showed the default I2C pins used for the nRF52840 development kit in the nominal Zephyr Devicetree. Then, I demonstrated how an overlay can be used to override this pin configuration and the final result.
An Iterative Approach to USART HAL Design using ChatGPT
Discover how to leverage ChatGPT and an iterative process to design and generate a USART Hardware Abstraction Layer (HAL) for embedded systems, enhancing code reusability and scalability. Learn the step-by-step journey, improvements made, and the potential for generating HALs for other peripherals.
Introduction to Microcontrollers - More On GPIO
Now that we have our LED Blinky program nailed down, it's time to look more closely at outputs, add button/switch inputs, and work with reading inputs and driving outputs based on those inputs. [quicklinks] It's ON - No, It's...
How to Read a Power MOSFET Datasheet
One of my pet peeves is when my fellow engineers misinterpret component datasheets. This happened a few times recently in separate instances, all involving power MOSFETs. So it’s time for me to get on my soapbox. Listen up! I was going to post...
When a Mongoose met a MicroPython
This is more a framework than an actual application, with it you can integrate MicroPython and Cesanta's Mongoose.
Mongoose runs when called by MicroPython and is able to run Python functions as callbacks for the events you decide in your event handler. The code is completely written in C, except for the example Python callback functions, of course. To try it, you can just build this example on a Linux machine, and, with just a small tweak, you can also run it on any ESP32 board.
Return of the Delta-Sigma Modulators, Part 1: Modulation
About a decade ago, I wrote two articles: Modulation Alternatives for the Software Engineer (November 2011) Isolated Sigma-Delta Modulators, Rah Rah Rah! (April 2013) Each of these are about delta-sigma modulation, but they’re...
What is Pulse Width Modulation and How Does It Work?
Pulse Width Modulation (PWM) is a technique used to control the average voltage supplied to a device or component by adjusting the width of a series of pulses. It works by rapidly turning a signal on and off at a specific frequency. The crucial element of PWM is the duty cycle, which represents the percentage of time the signal is “on” (high voltage) compared to the total time of one cycle.

Quaternions and the spatial rotations in motion enabled wearable devices. Exploiting the potential of smart IMUs attitude estimation.
Have you always wondered what a quaternion is? this is your post. Attitude or spatial orientation analysis is a powerful element in wearable devices (and many other systems). Commercially available sensors can provide this information out-of-the-box without requiring complex additional implementation of sensor fusion algorithms. Since these are already on-chip solutions devices can serve as a way to explore and analyze motion in several use cases. Mathematical analysis for processing quaternion is presented along with a brief introduction to them, Although they are not really easy to visualise, a couple fairly simple examples are provided which may allow you to gain some intuition on what's the logic behind them.

Turn It On Again: Modeling Power MOSFET Turn-On Dependence on Source Inductance
This is a short article explaining how to analyze part of the behavior of a power MOSFET during turn-on, and how it is influenced by the parasitic inductance at the source terminal. The brief qualitative reason that source inductance is undesirable is that it uses up voltage when current starts increasing during turn-on (remember, V = L dI/dt), voltage that would otherwise be available to turn the transistor on faster. But I want to show a quantitative approximation to understand the impact of additional source inductance, and I want to compare it to the effects of extra inductance at the gate or drain.

A design non-methodology
Although writing an RTOS or kernel may be an interesting project, it is unlikely to be a wise course of action.
Working with Microchip PIC 8-bit GPIO
The third in a series of five posts looks at GPIO with PIC 8-bit microcontrollers. After a detailed review of the registers for configuring and managing GPIO on the PIC18F47Q10 processor, a basic application is stood up programming those registers to blink external LEDs at 0.5Hz.
Blinkenlights 2.0
Nothing spells old movie computers like a panel of randomly blinking lights, but in fact, these so-called "blinkenlights" can be valuable indicators - especially in embedded systems where the user interface must be minimal, small and cheap. Control of these lights can be achieved using a very simple, real-time interpreted script, and this kind of solution may be extended to other and more complex embedded tasks.
The volatile keyword
Although the C keyword volatile is very useful in embedded applications, care is needed to use it correctly and vigilance is required to ensure its correct implementation by compilers.
When a Mongoose met a MicroPython
This is more a framework than an actual application, with it you can integrate MicroPython and Cesanta's Mongoose.
Mongoose runs when called by MicroPython and is able to run Python functions as callbacks for the events you decide in your event handler. The code is completely written in C, except for the example Python callback functions, of course. To try it, you can just build this example on a Linux machine, and, with just a small tweak, you can also run it on any ESP32 board.
Getting Started With CUDA C on an Nvidia Jetson: GPU Architecture
In the previous blog post (Getting Started With CUDA C on Jetson Nvidia: Hello CUDA World!) I showed how to develop applications targeted at a GPU on a Nvidia Jetson Nano. As we observed in that blog post, performing a calculation on a 1-D array on a GPU had no performance benefit compared to a traditional CPU implementation, even on an array with many elements. In this blog post, we will learn about the GPU architecture to better explain the behavior and to understand the applications where a GPU shines (hint: it has to do with graphics).
Understanding Microchip 8-bit PIC Configuration
The second post of a five part series picks up getting started developing with Microchip 8-bit PIC Microcontroller by examining the how and why of processor configuration. Topics discussed include selecting the oscillator to use during processor startup and refining the configuration once the application starts. A walk through of the code generated by the Microchip IDE provides a concrete example of the specific Configuration Word and SFR values needed to configure the project specific clock configuration.
C to C++: Templates and Generics – Supercharging Type Flexibility
"C to C++: Templates and Generics – Supercharging Type Flexibility" illuminates the rigidity of C when managing multiple types and the confusion of code replication or macro complexity. In contrast, C++ offers templates, acting as type-agnostic blueprints for classes and functions, which allows for the creation of versatile and reusable code without redundancy. By using templates, developers can define operations like add once and apply them to any data type, simplifying codebases significantly. Generics further this concept, enabling a single code structure to handle diverse data types efficiently—a boon for embedded systems where operations must be performed on varying data, yet code efficiency is critical due to resource limitations. The blog walks through practical applications, showcasing how templates streamline processes and ensure type safety with static_assert, all while weighing the pros and cons of their use in embedded software, advocating for careful practice to harness their full potential.


Linear Feedback Shift Registers for the Uninitiated, Part V: Difficult Discrete Logarithms and Pollard's Kangaroo Method
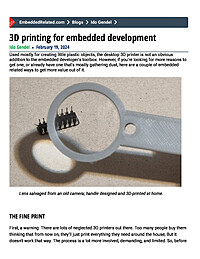
3D printing for embedded development
Used mostly for creating little plastic objects, the desktop 3D printer is not an obvious addition to the embedded developer's toolbox. However, if you're looking for more reasons to get one, or already have one that's mostly gathering dust, here are a couple of embedded-related ways to get more value out of it.
Getting Started With Zephyr: Devicetree Overlays
In this blog post, I show how the Devicetree overlay is a valuable construct in The Zephyr Project RTOS. Overlays allow embedded software engineers to override the default pin configuration specified in Zephyr for a particular board. In this blog post, I use I2C as an example. Specifically, I showed the default I2C pins used for the nRF52840 development kit in the nominal Zephyr Devicetree. Then, I demonstrated how an overlay can be used to override this pin configuration and the final result.
C to C++: Using Abstract Interfaces to Create Hardware Abstraction Layers (HAL)
In C to C++, we've been exploring how to transition from a C developer to a C++ developer when working in embedded system. In this post, we will explore how to leverage classes to create hardware abstraction layers (HAL). You'll learn about the various inheritance mechanisms, what an virtual function is, and how to create an abstract class.

Who needs source code?
Many developers feel that the supplying source code is essential for licensed software components. There are other perspectives, including the possibility of it being an actual disadvantage. Even the definition of source code has some vagueness.
A Second Look at Slew Rate Limiters
I recently had to pick a slew rate for a current waveform, and I got this feeling of déjà vu… hadn’t I gone through this effort already? So I looked, and lo and behold, way back in 2014 I wrote an article titled Slew Rate...